 01
Supremacy Robotics Engineering
From cell to fleet, one control layer
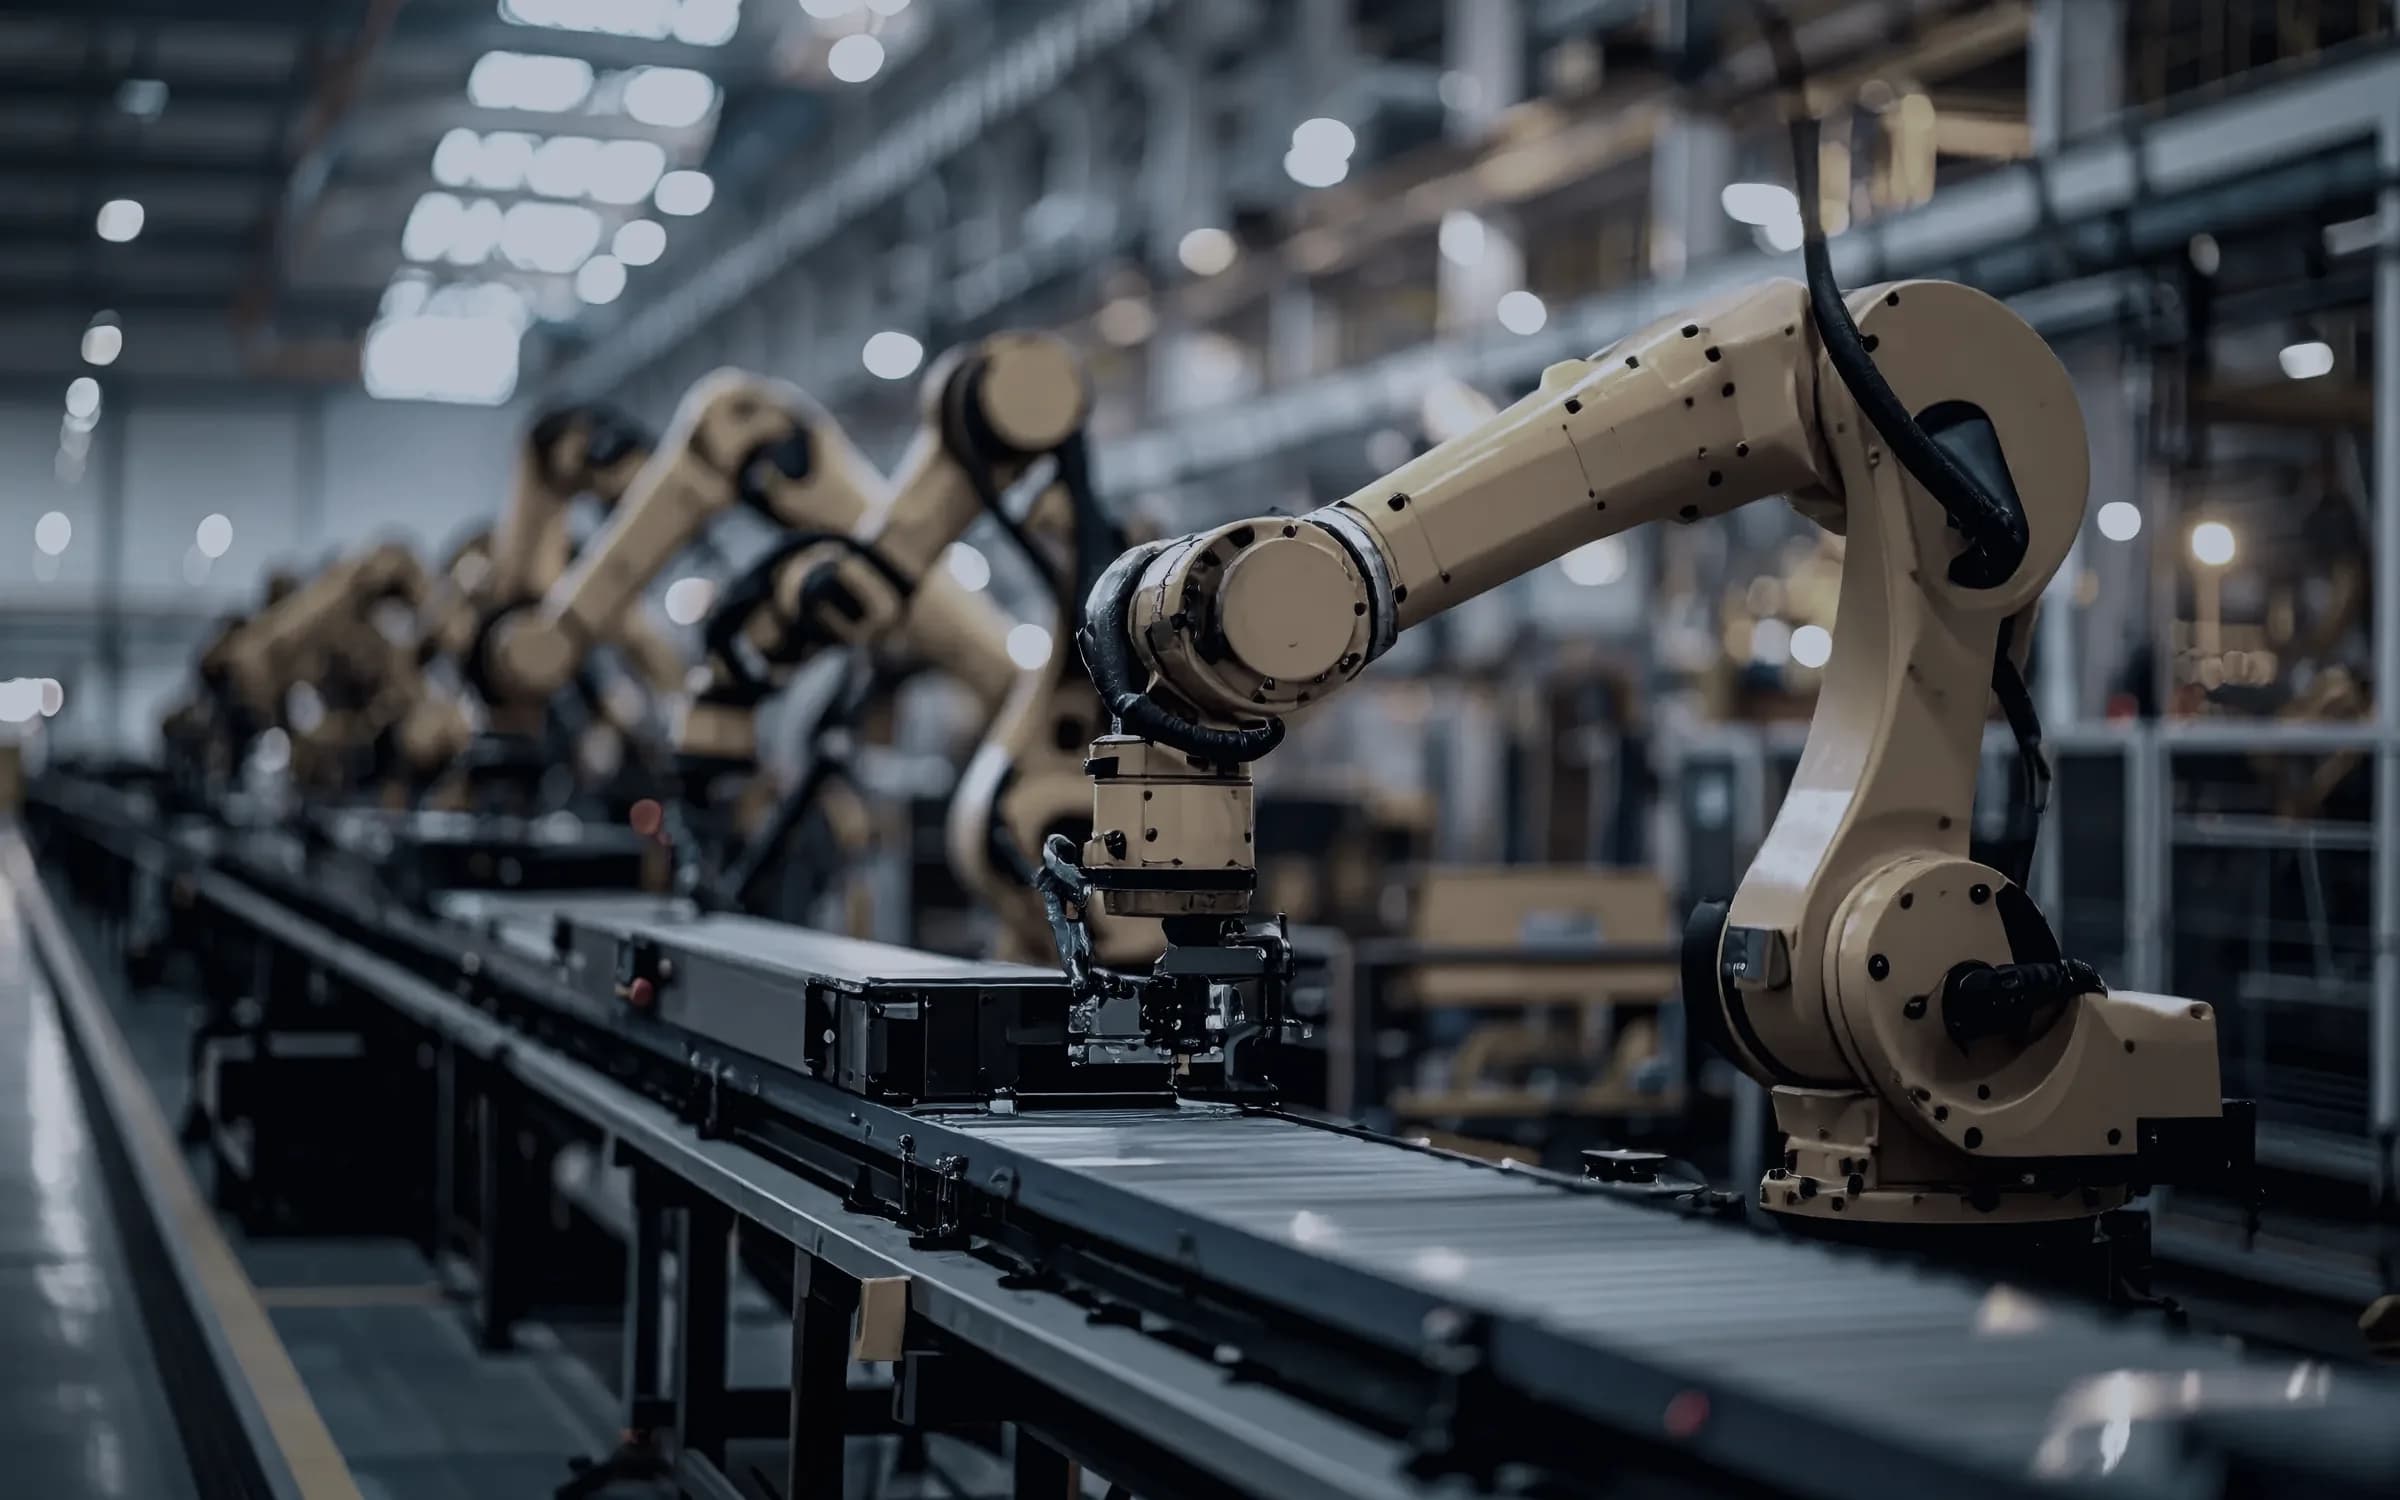
Supremacy builds robotics systems that survive the floor — cell integration, motion and safety, autonomous navigation, and fleet orchestration engineered for production shifts, not showroom runs.
Built for production and automation teams running robots on live lines
01Overview
The cellMost robotics programmes stall at cell one. We design the gripper, the fixturing, the vision, and the safety envelope together, so the first cell runs a full shift unattended and the second one is a copy rather than a project.
01/ 02
The cell
Make the first robot earn its keep
Most robotics programmes stall at cell one. We design the gripper, the fixturing, the vision, and the safety envelope together, so the first cell runs a full shift unattended and the second one is a copy rather than a project.
- 01
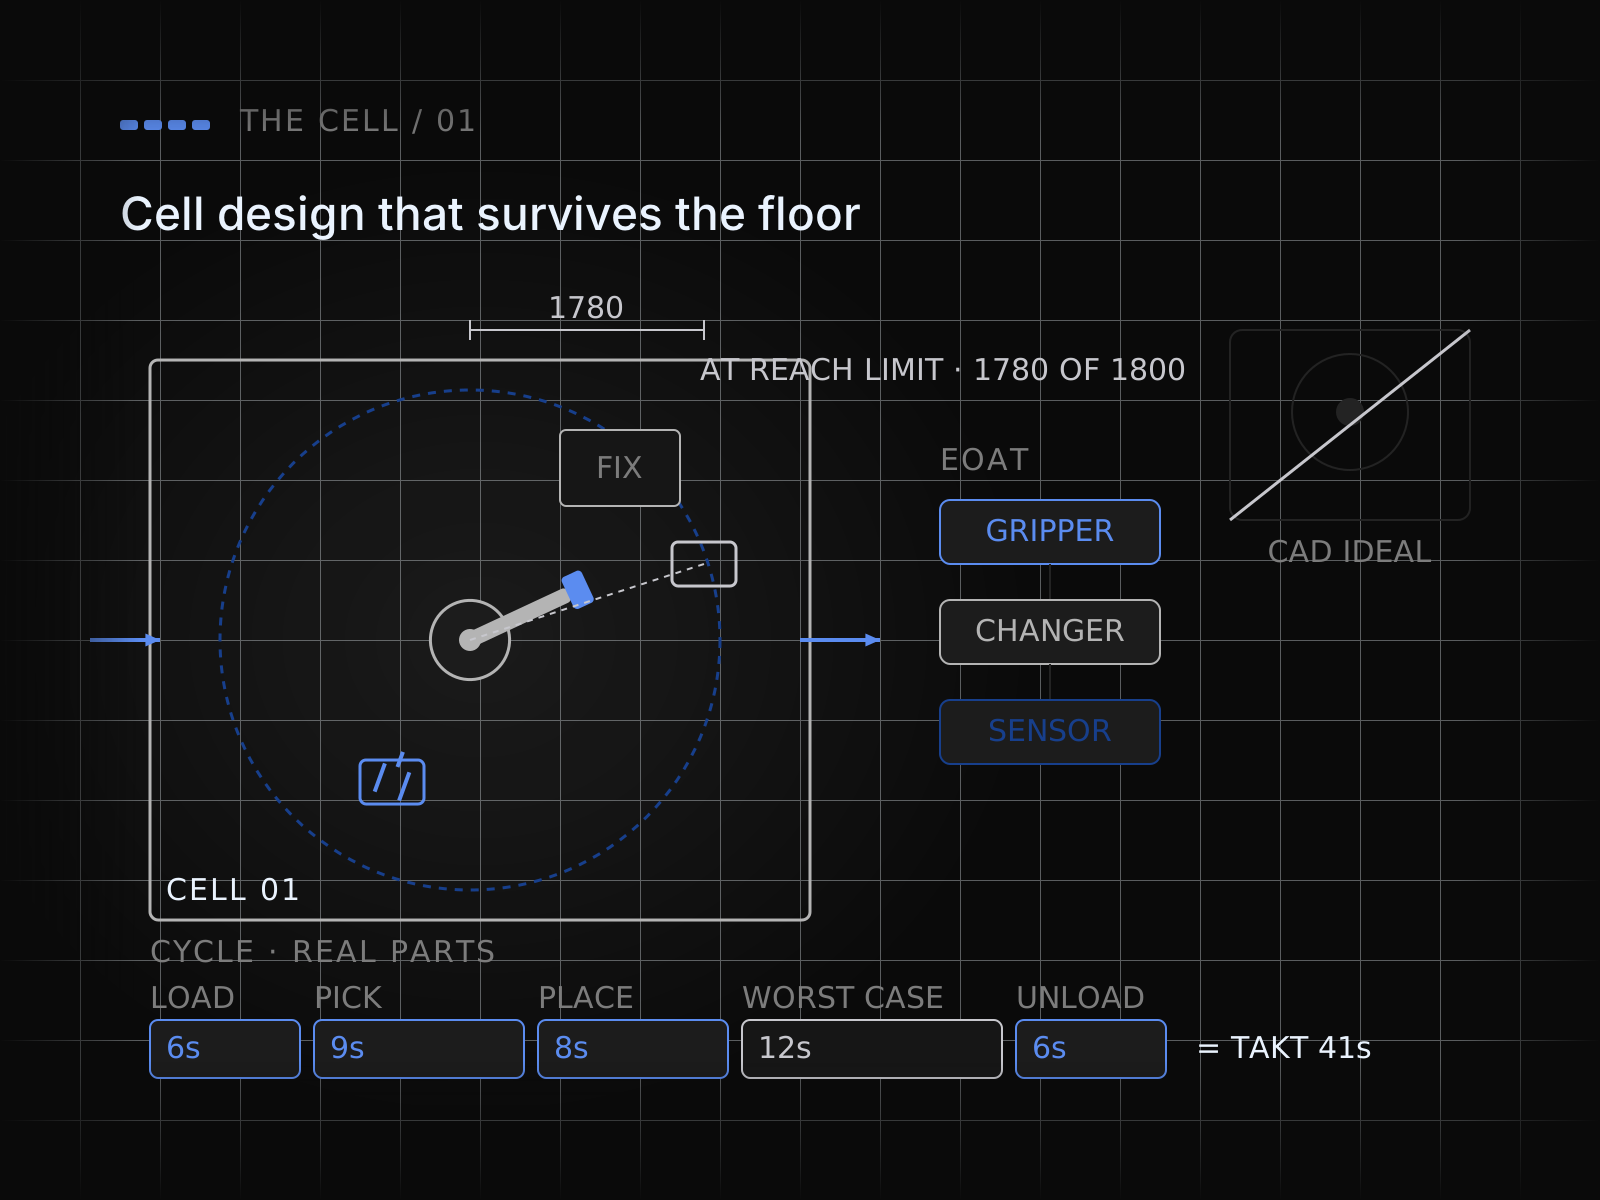
Cell design that survives the floor
Reach studies, fixturing, and end-of-arm tooling worked out against your real parts and real cycle time, not a CAD model of an ideal one.
- 02
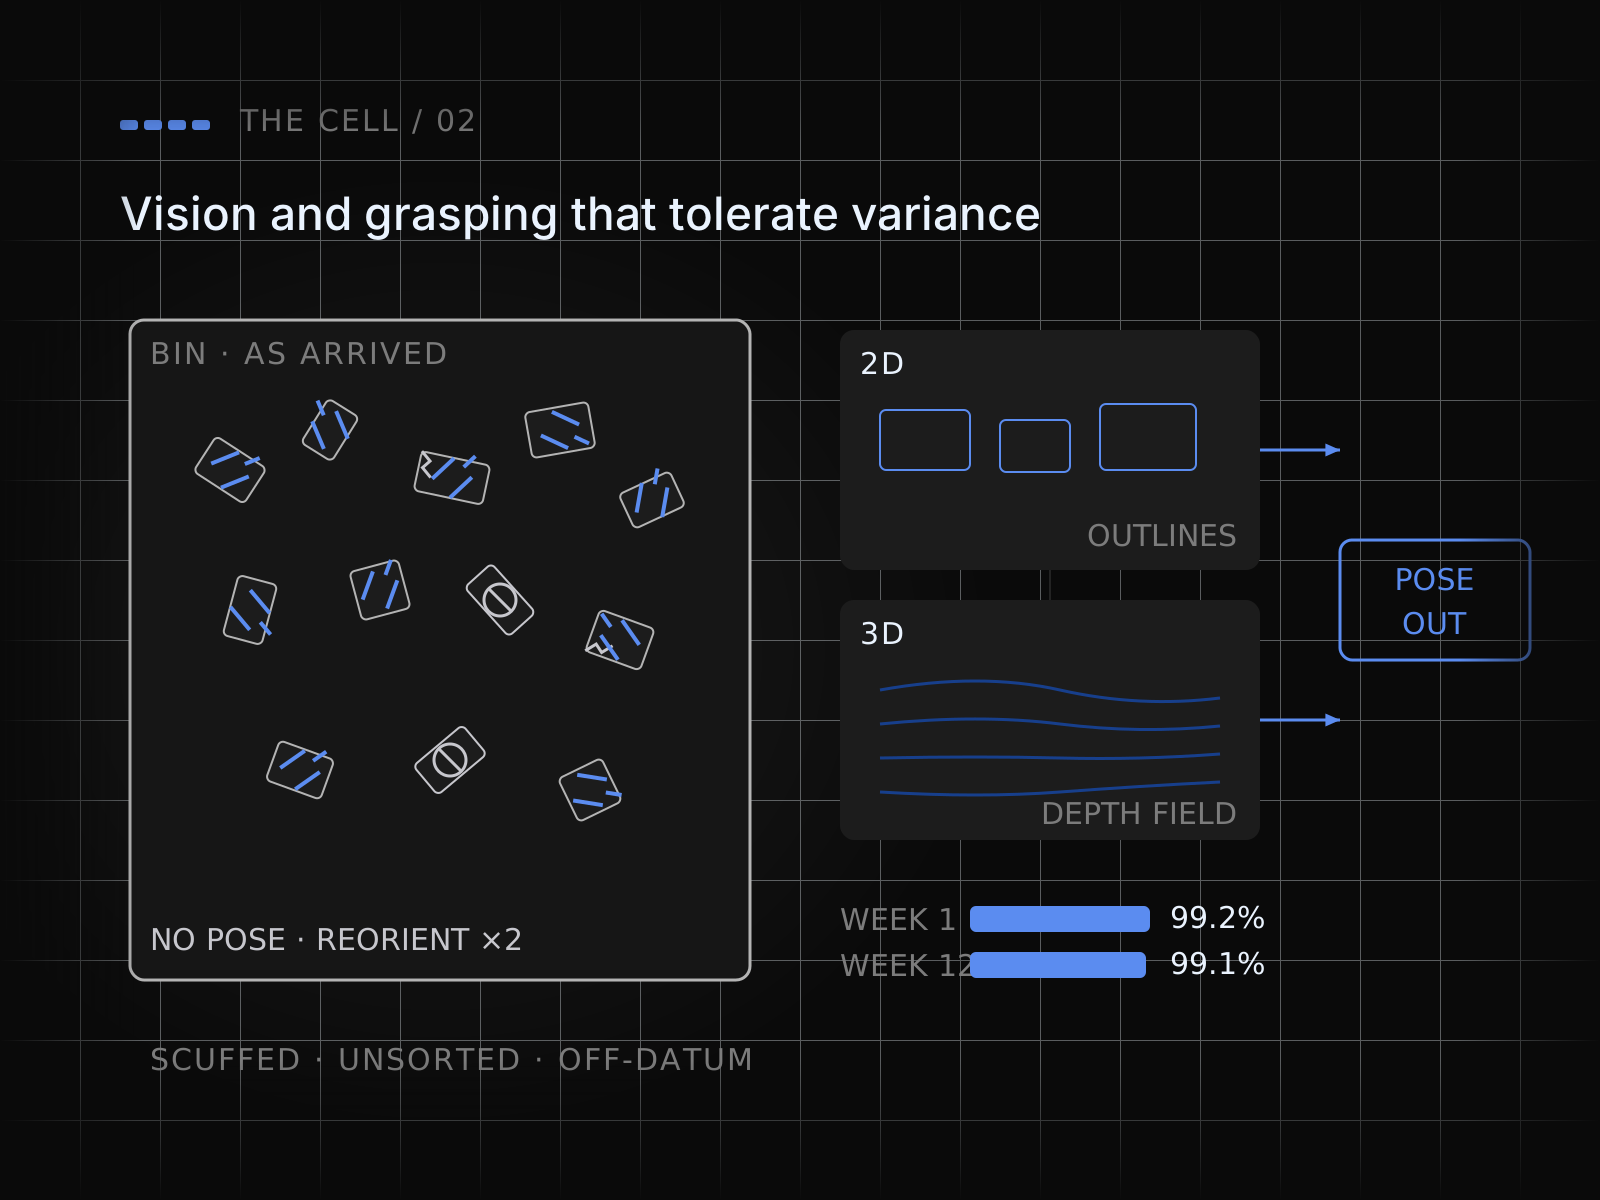
Vision and grasping that tolerate variance
2D and 3D perception tuned on parts as they actually arrive — scuffed, unsorted, and off-datum — so bin picking keeps working after week one.
- 03
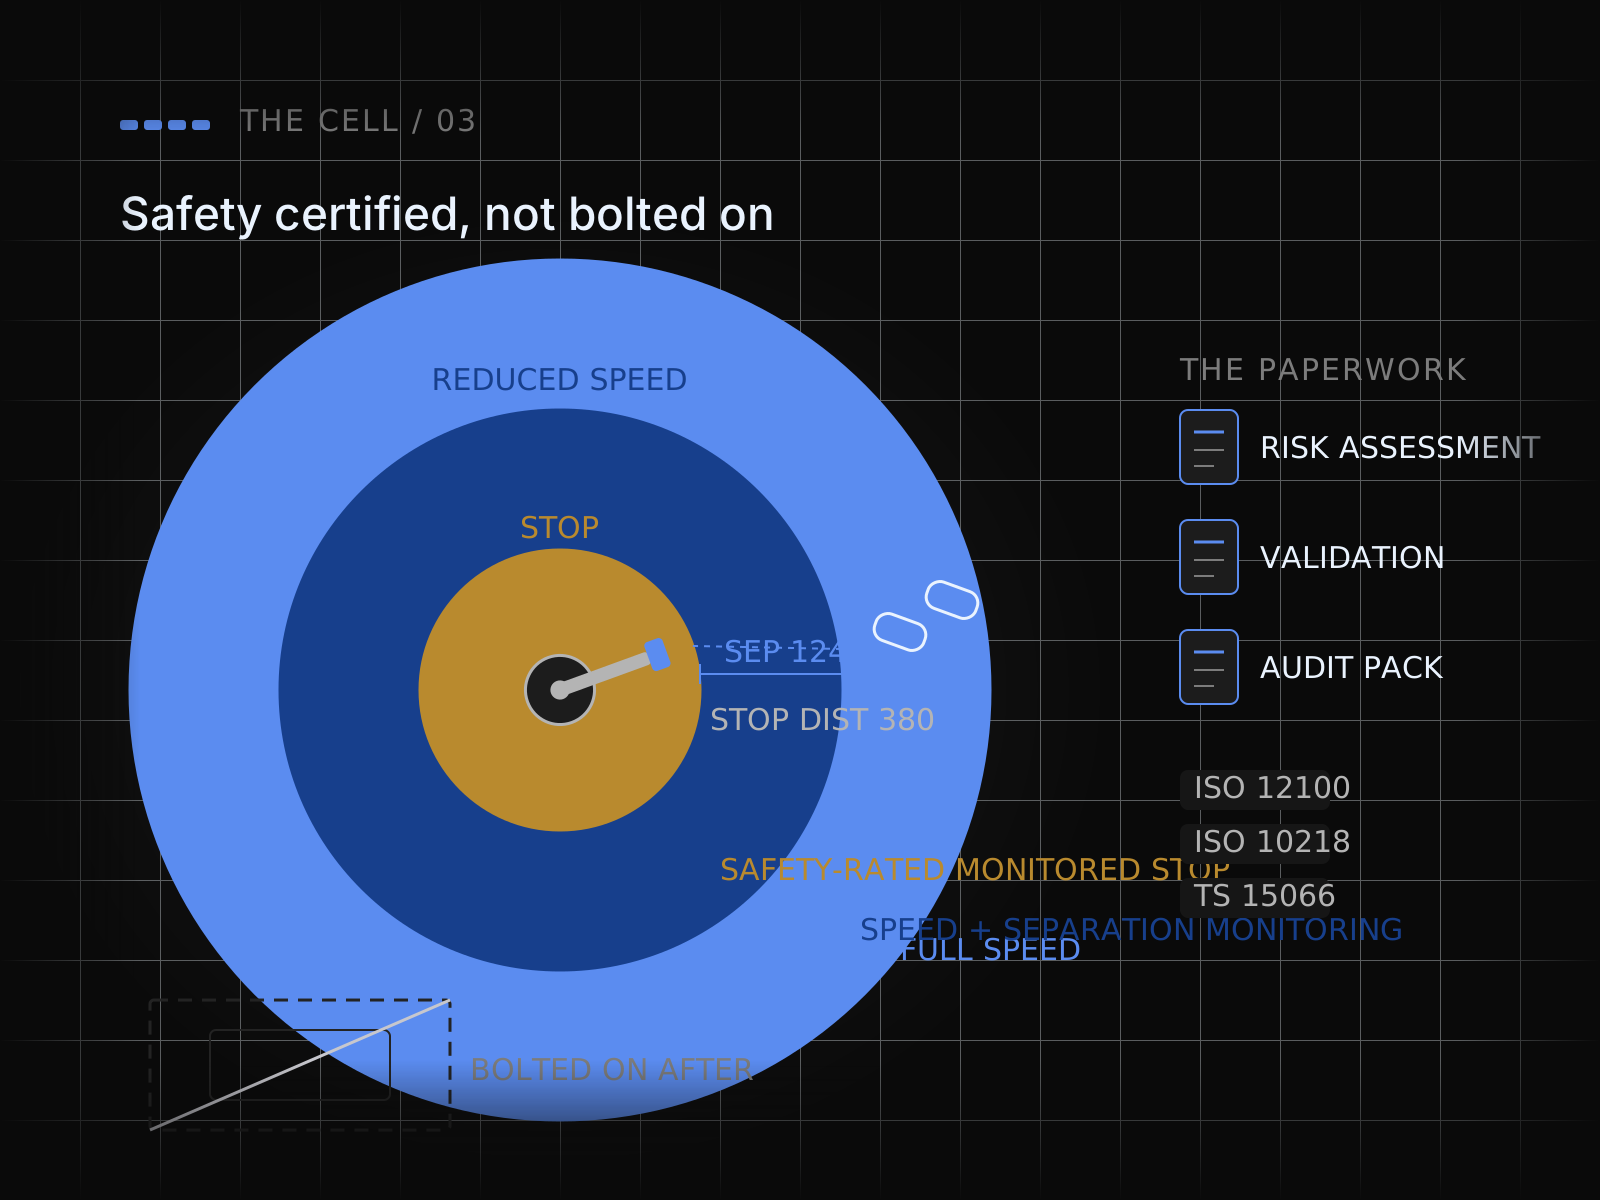
Safety certified, not bolted on
Risk assessment, safety-rated monitored stop, speed and separation monitoring, and the paperwork your auditor asks for, designed in from the first sketch.
- 04
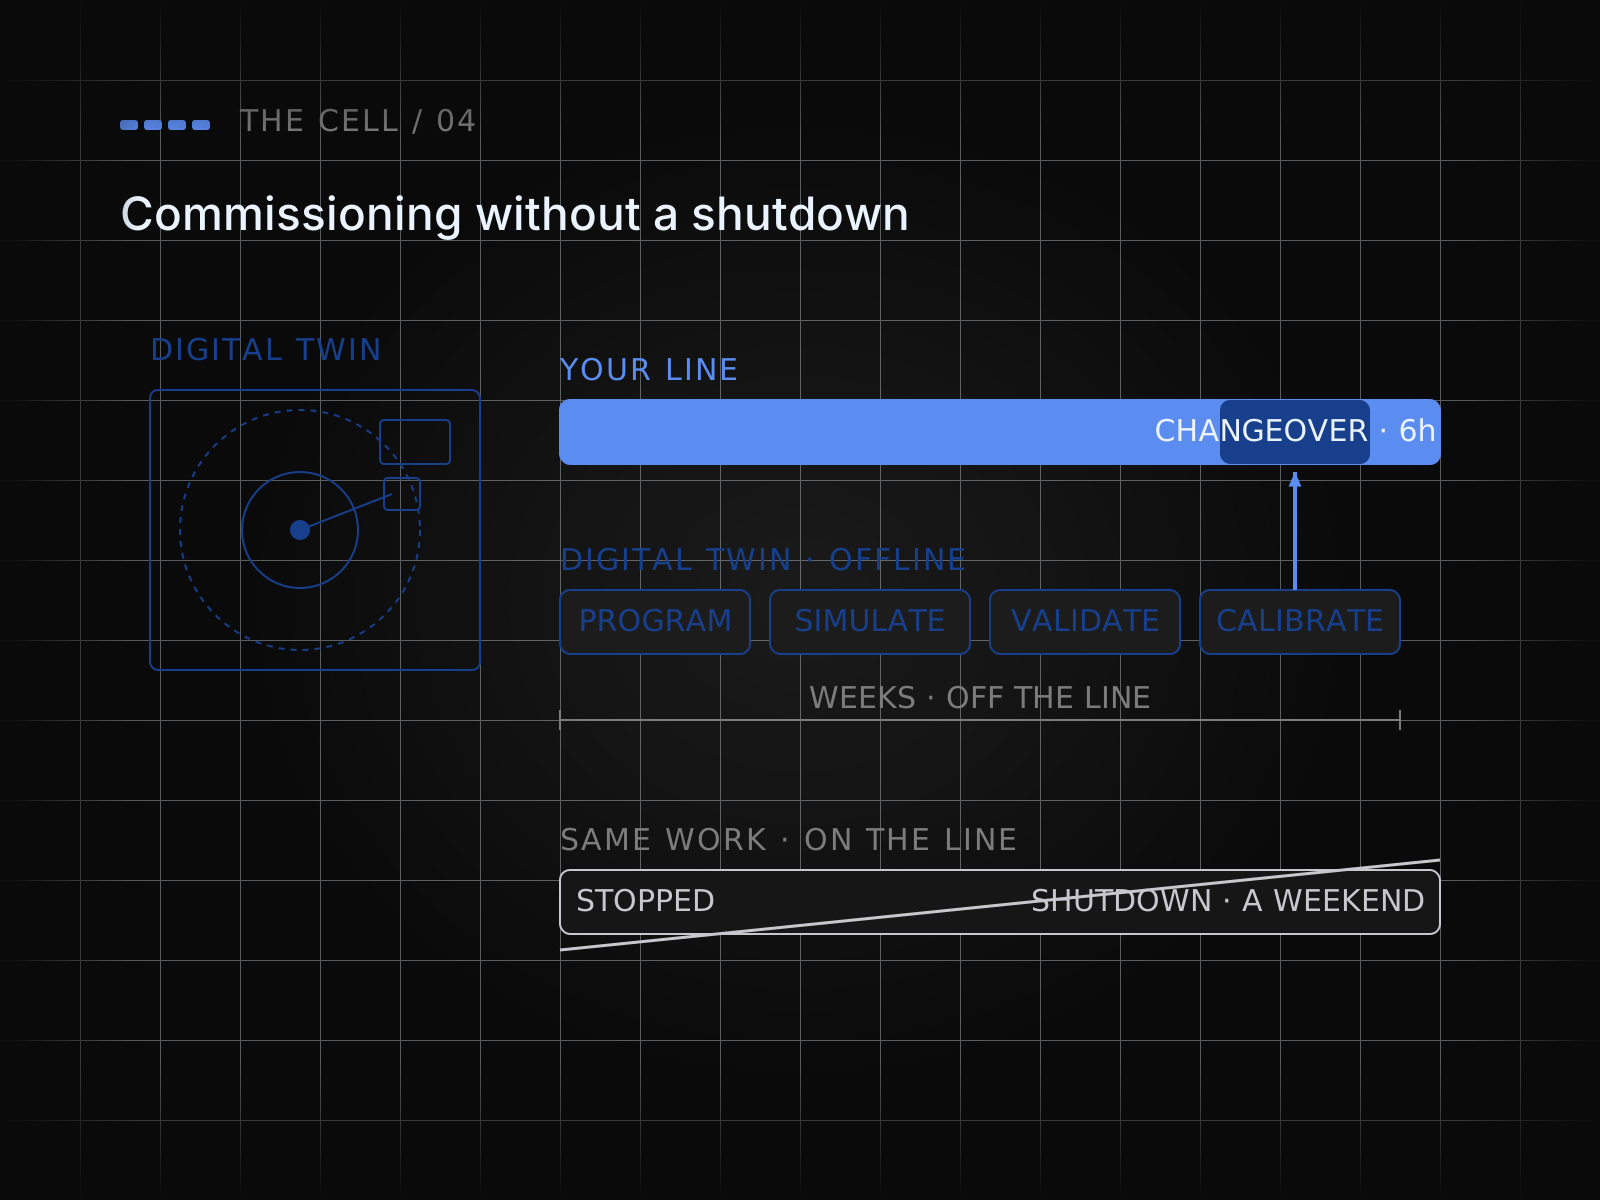
Commissioning without a shutdown
Digital twin and offline programming take the integration off the line, so the cell arrives calibrated and the changeover costs hours instead of a weekend.
02/ 02
The fleet
Run a hundred robots like one system
A robot is an asset; a fleet is an operating decision. Orchestration, traffic, and telemetry belong in one layer that dispatch, maintenance, and finance all read from — so adding the fiftieth robot is an order, not another integration.
- 05
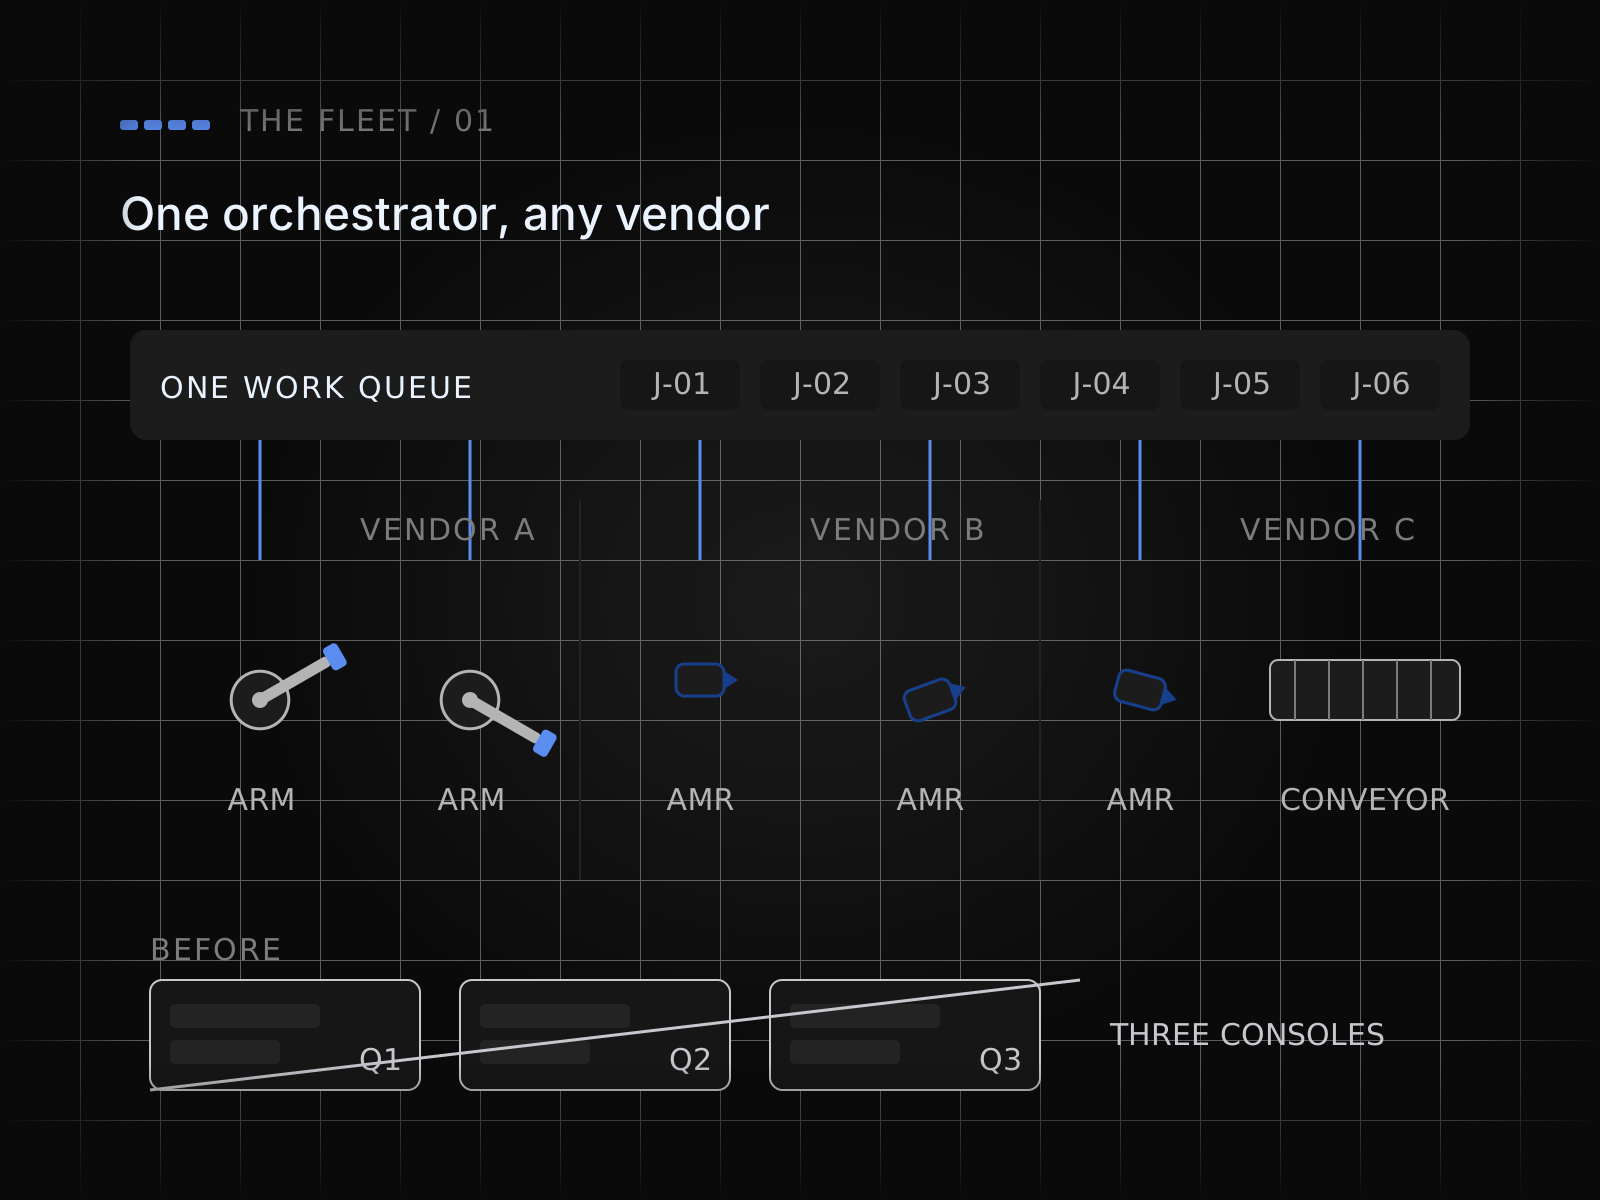
One orchestrator, any vendor
Arms, AMRs, and conveyors from different suppliers take work from a single scheduler, so the mix on the floor is a procurement choice rather than a lock-in.
- 06
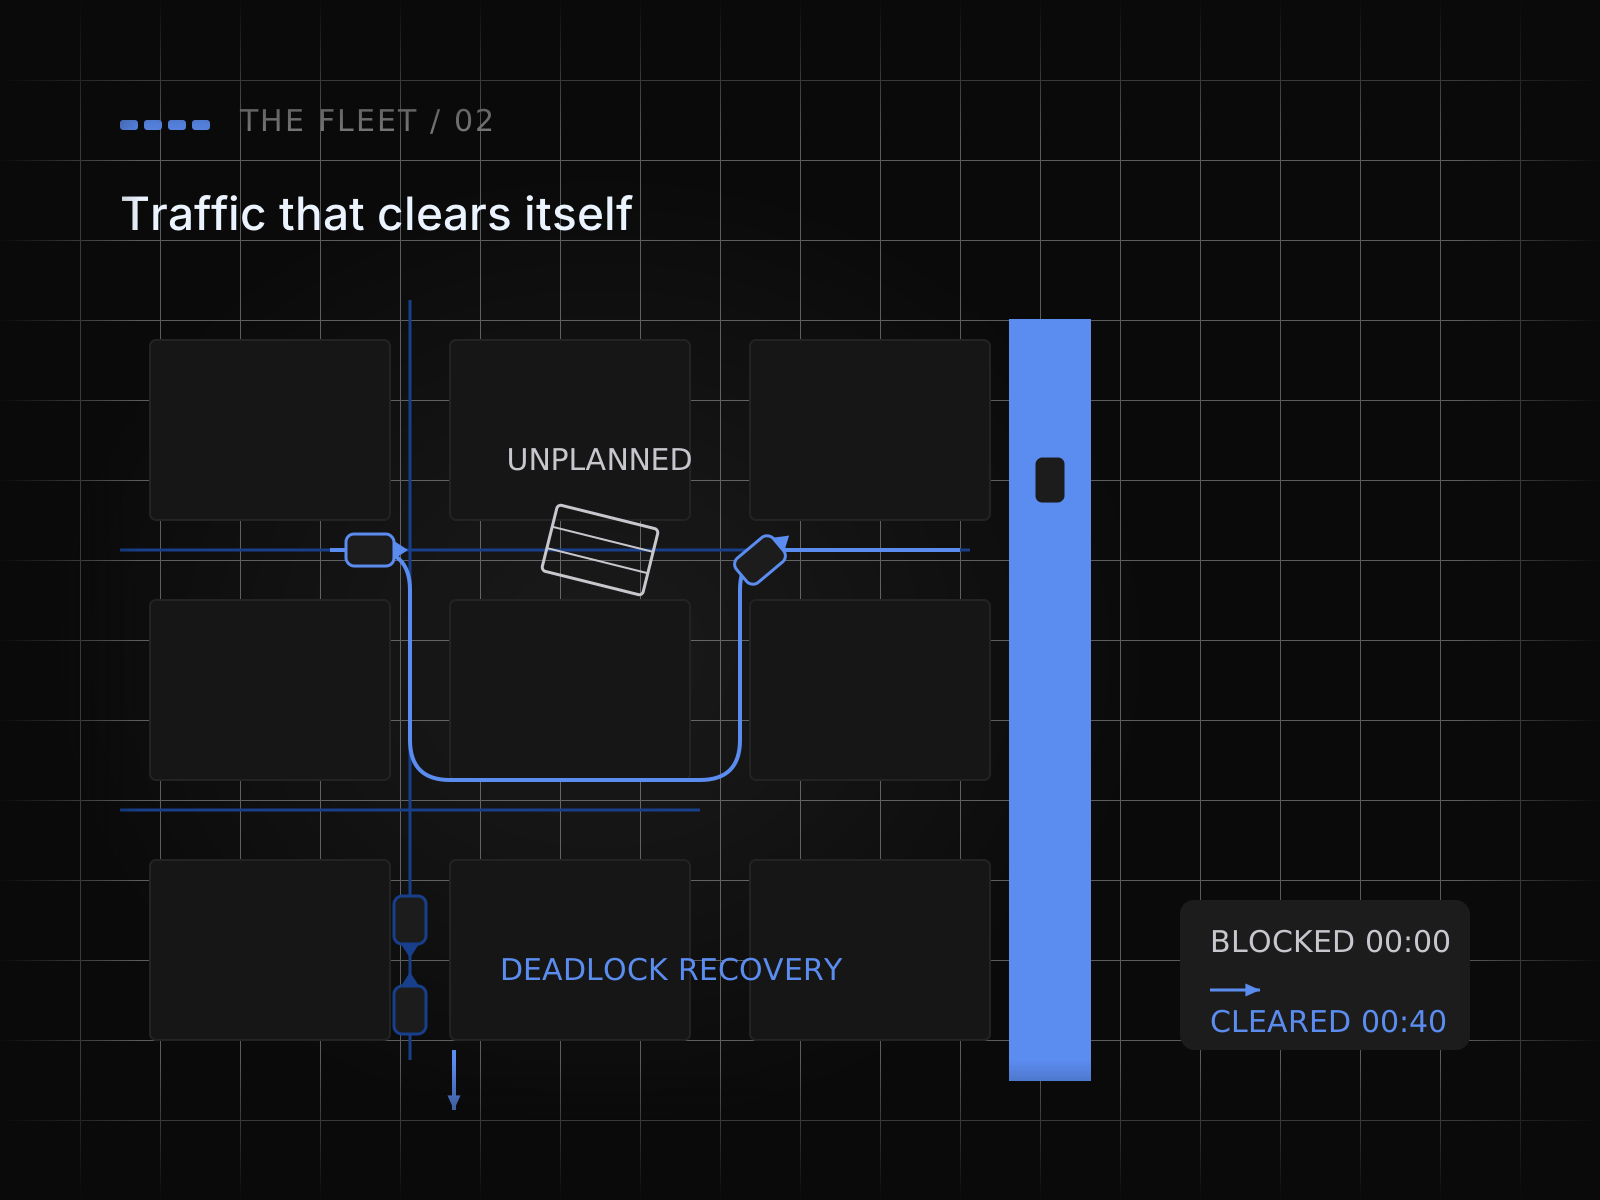
Traffic that clears itself
Live path planning, deadlock recovery, and priority lanes keep the aisles moving when a pallet lands where it should not have.
- 07
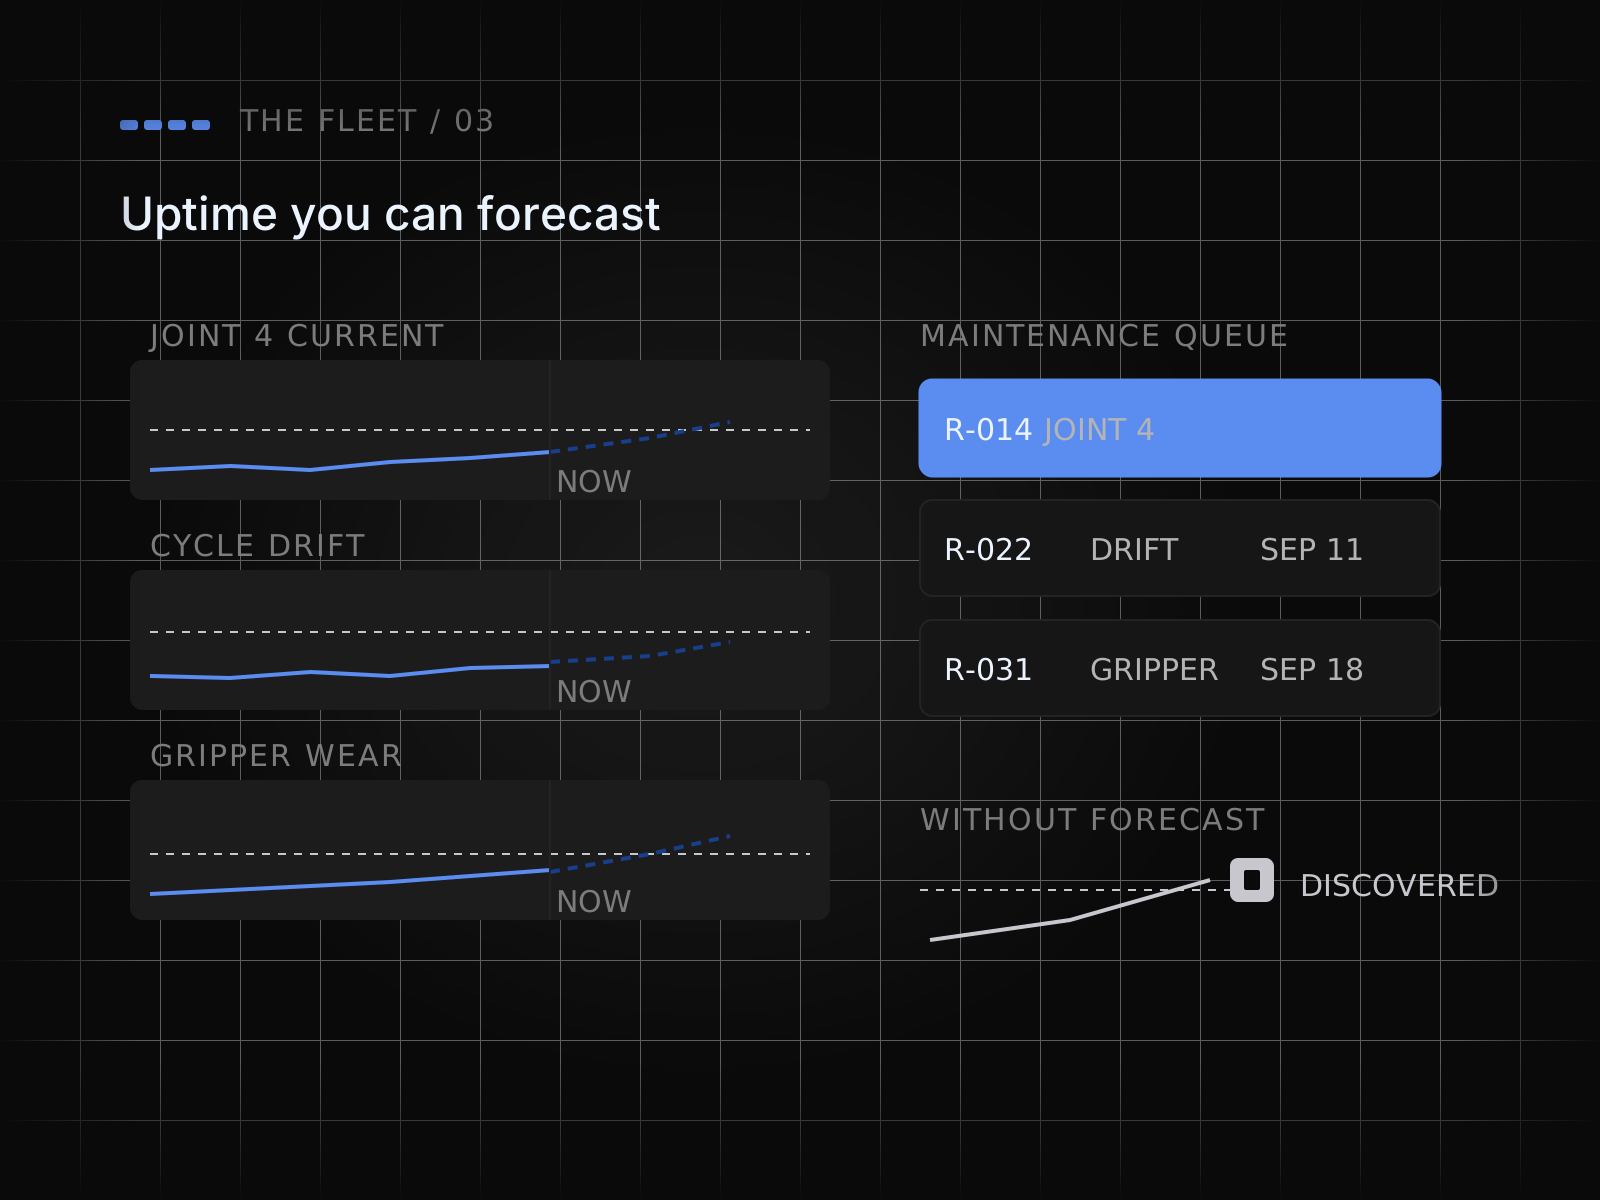
Uptime you can forecast
Joint current, cycle drift, and gripper wear roll up into a maintenance queue, so a service window is scheduled instead of discovered.
- 08
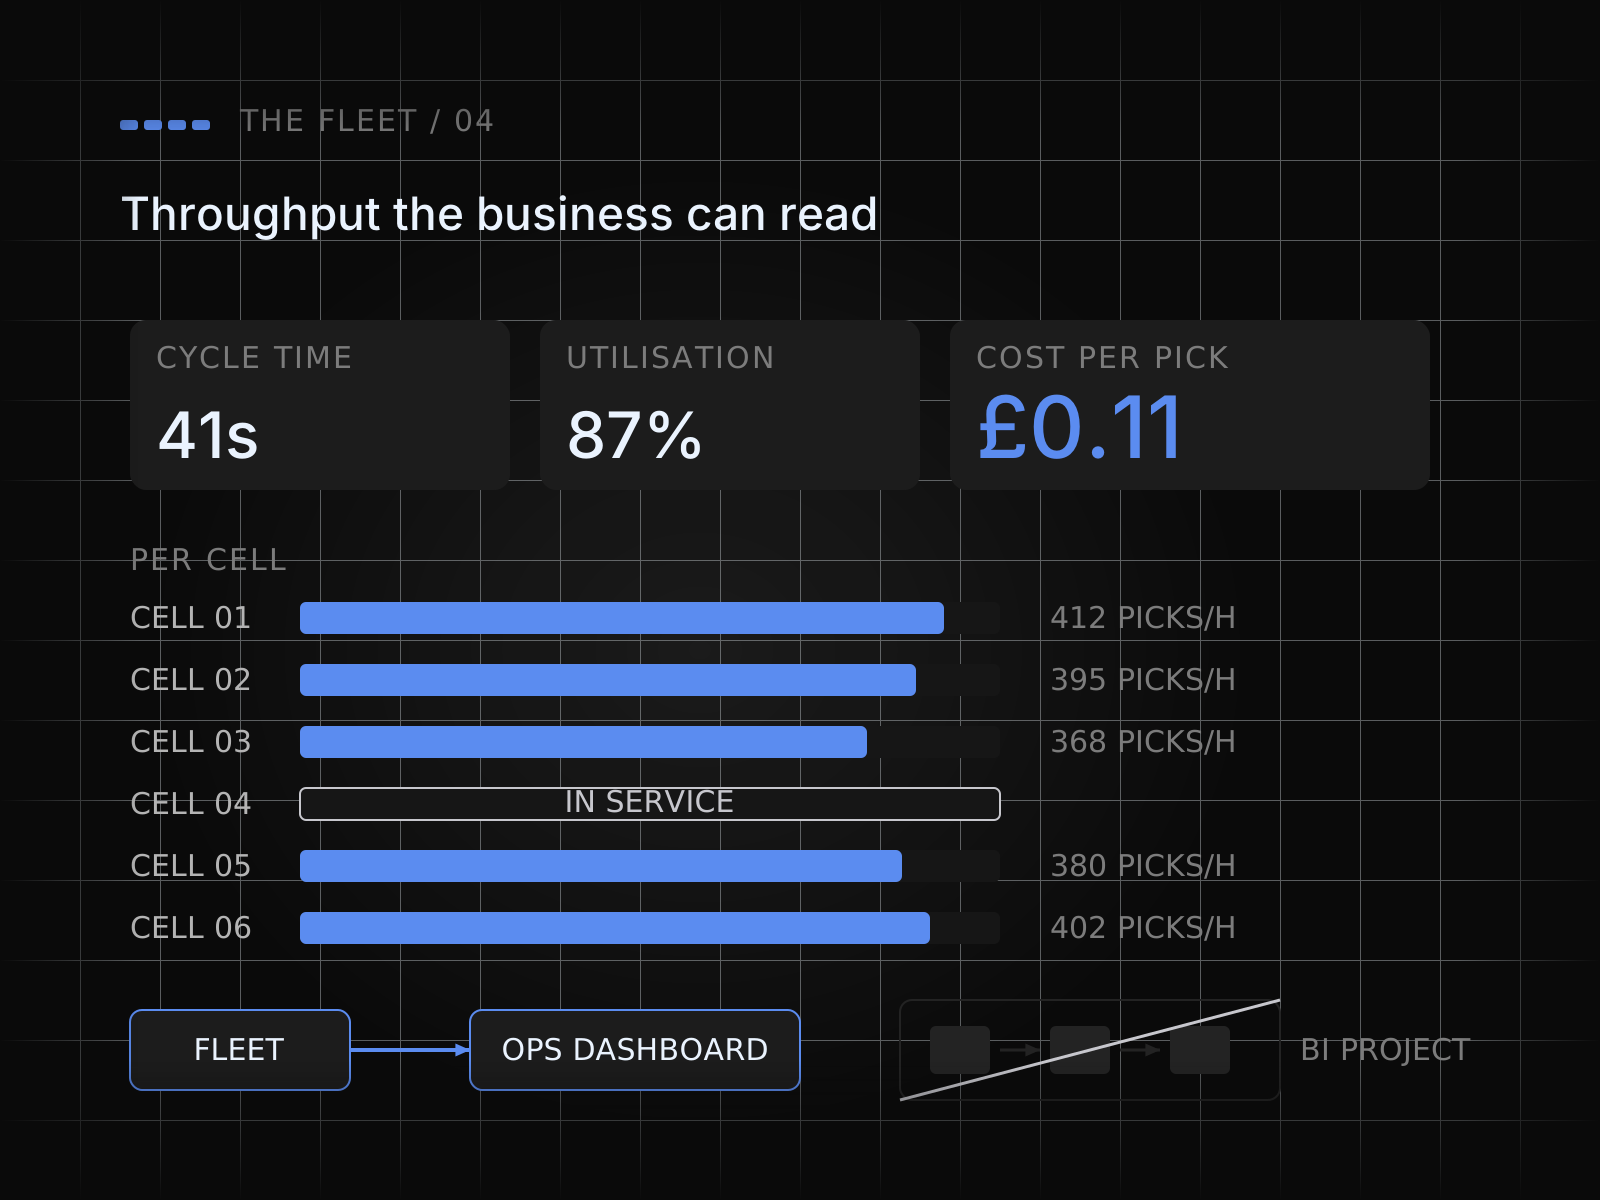
Throughput the business can read
Cycle time, utilisation, and cost per pick land in the same dashboards as the rest of operations, without a BI project to get there.
At a glance
Every capability, at a glance
8 figures, one per capability. Open any to read it in full.
How it runs
From first call to running unattended
Every engagement runs the same five steps, whatever the service.
- 01
Map the process
We sit with the people who do the work today and write down every step, exception and hand-off before anything is built.
- 02
Build against a golden set
A held-out set of real cases, agreed with you, is the bar each build has to clear before it goes anywhere near production.
- 03
Run beside the team
The system runs in parallel with the team for as long as it takes, and every disagreement between them is reviewed together.
- 04
Hand over the keys
The code, the prompts, the evaluation set and the runbooks are handed over in your accounts, under your keys.
- 05
Keep it running
We watch the runs, retrain and repair as the inputs drift, or train your own team to do the same.
Outcomes
What this looks like when it lands.
01 A precision machinist runs lights-out on the night shift
Two collaborative cells with vision-guided loading now cover the third shift unattended, turning a hiring problem the plant could not solve into eight hours of extra capacity a day.
02 Forty autonomous robots, three vendors, one traffic layer
A distribution centre replaced three vendor consoles with a single orchestrator, cutting aisle congestion incidents to near zero and lifting picks per hour by a fifth.
03 Cleanroom handling without a single line stoppage
Offline programming and a digital twin let a semiconductor supplier commission wafer-handling robots between production runs, with no scheduled downtime at all.
Details
On the spec sheet.
- Service
- Robotics & Physical Automation
- Group
- Physical & operations
- Capabilities
- 8
- Engagement
- Map, build, run beside the team, hand over, keep running
- Ownership
- Your accounts, your keys, your region
FAQs
Asked before signing.
What does Supremacy Robotics Engineering cover?
The whole path from feasibility to a running fleet — cell design, end-of-arm tooling, vision, motion and safety, PLC and robot programming, fleet orchestration software, and the integrations into MES, WMS, and maintenance systems that make the robots part of the operation.
Do you work with the robots we already own?
Yes. We integrate ABB, FANUC, KUKA, Universal Robots, Yaskawa, and the common AMR platforms, and our orchestration layer is vendor-neutral by design, so an existing estate is a starting point rather than something to replace.
Cobot or industrial arm — how do you decide?
By cycle time, payload, and the safety envelope the work actually needs. Collaborative arms win where people and parts share a space and the takt allows it; fenced industrial cells win where speed and payload dominate. We size that before anything is quoted.
How do you handle safety and certification?
Every cell starts with an ISO 12100 risk assessment and is designed against ISO 10218 and TS 15066, with safety-rated hardware, validated stopping distances, and the documentation pack your notified body or internal auditor will ask to see.
How long before the first cell is producing?
A single well-scoped cell typically runs feasibility to production in twelve to sixteen weeks, with offline programming and a digital twin doing the integration work in parallel so the time on your floor is measured in days.